Robotics software engineer in Abu Dhabi. I build mission-control and autonomy software for drones, ground robots and quadrupeds, and write about robotics, Rust, Neovim and whatever else I’m tinkering with. Raw notes and stories live in my digital garden.
Selected projects
 oxmpl
Oxidised Motion-Planning Library. Sampling-based planners in Rust, with Python and WASM bindings.
 px4-log-tool
All-in-one CLI for PX4 flight logs. Converts between ulog, ROS 2 bags and CSV.
 ur5_gripper_control
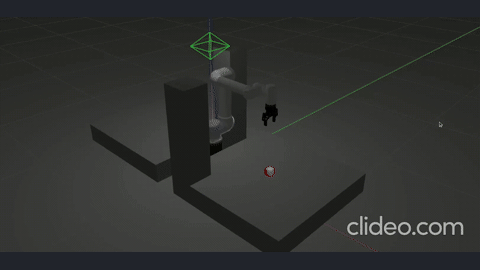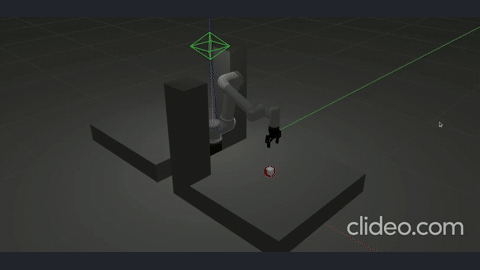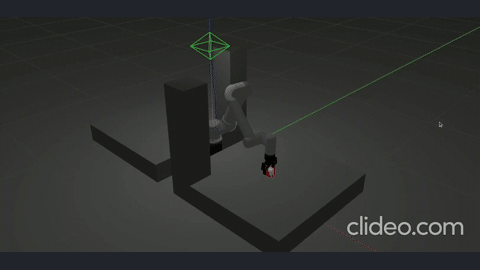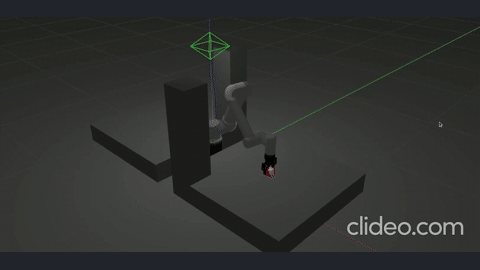
UR5 with a Robotiq gripper. Motion planning with MoveIt and workspace perception with Octomap.